Yangzheng Wu
Team Lead, Embodied AI Senior Researcher at Huawei Canada Research Institute

Markham, Ontario, Canada
I am an embodied AI and computer vision researcher working on vision-language-action models, reliable robot perception, and 6DoF object pose estimation. I am currently a Team Lead and Embodied AI Senior Researcher at Huawei Canada Research Institute.
My recent work focuses on long-horizon robot behavior, robustness of vision-language-action systems, and simulation-to-real learning. During my PhD at Queen’s University, supervised by Dr. Michael Greenspan, I developed keypoint voting methods for RGB-D, point-cloud, and self-supervised 6DoF object pose estimation.
Highlights include ranking No. 1 worldwide in the CoRL BEHAVIOR-1K 2026 Challenge and 4th worldwide in the NeurIPS 2025 BEHAVIOR-1K Challenge, and main contribution to the best-performing method on ITODD in the BOP 2022 6DoF Rigid Object Pose Estimation Challenge.
selected publications
- arXiv
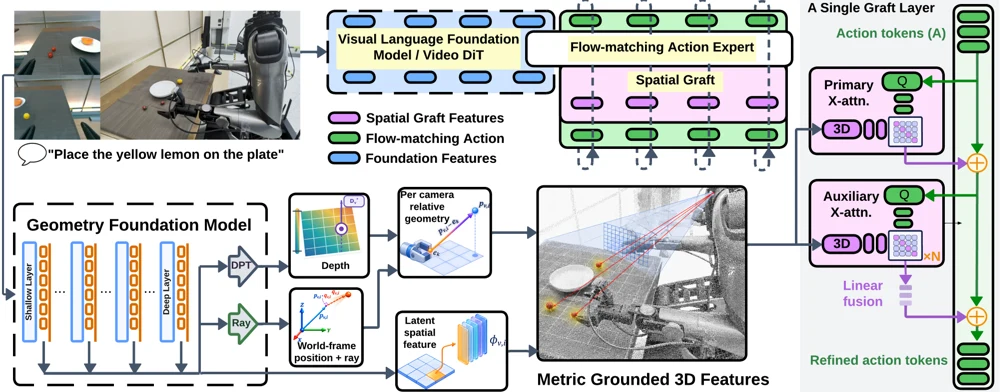 Spatial Grafting: Grounding 3D Features for Flow-Matching Robot PoliciesarXiv preprint arXiv:2609.35249, 2026
- arXiv
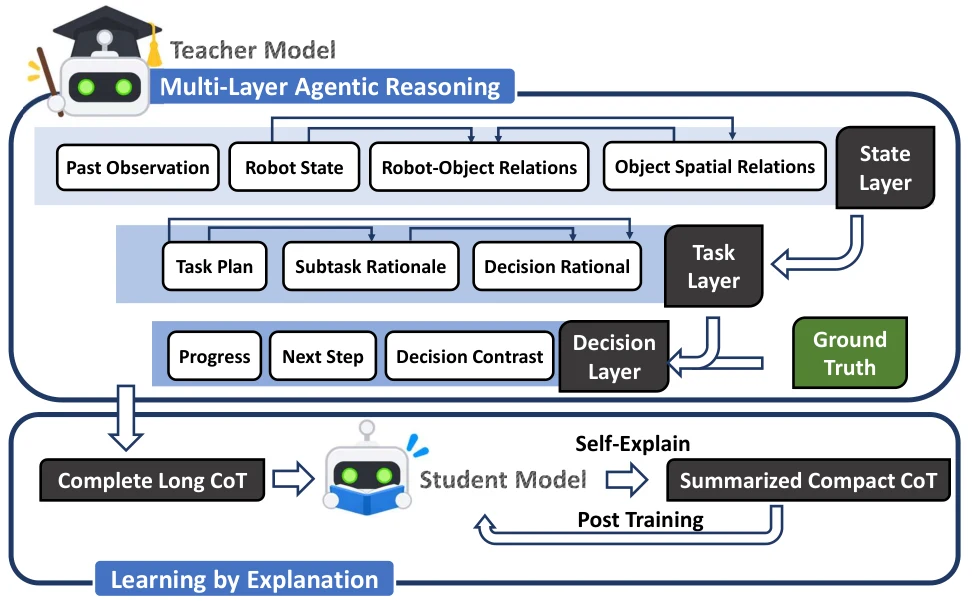 StageGuard: Learning Stage Transitions for Long-Horizon Robot Tasks via Agentic DistillationarXiv preprint arXiv:2609.20791, 2026
- RSS Workshop
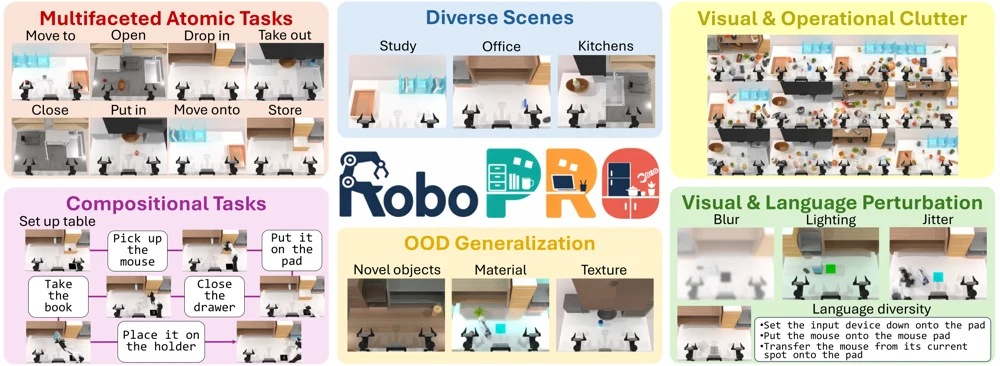 Data and Evaluation Protocols for Robust Robotic ManipulationIn Data-Centric Robotics Workshop at Robotics: Science and Systems (RSS), 2026
- ICRA
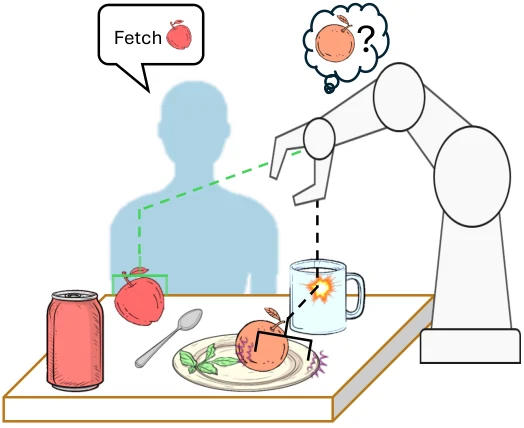 Distracted Robot: How Visual Clutter Undermine Robotic ManipulationIn IEEE International Conference on Robotics and Automation (ICRA), 2026
- arXiv
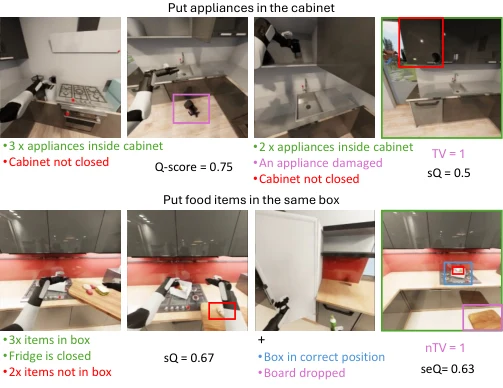
- arXiv
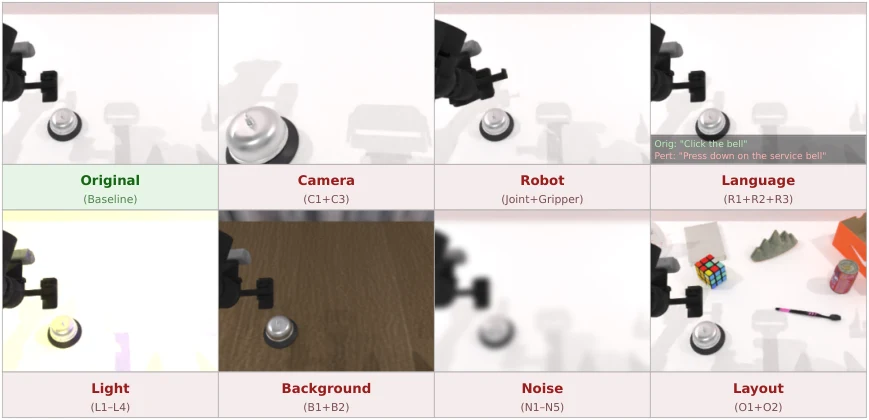 Do World Action Models Generalize Better than VLAs? A Robustness StudyarXiv preprint arXiv:2603.22078, 2026
- arXiv
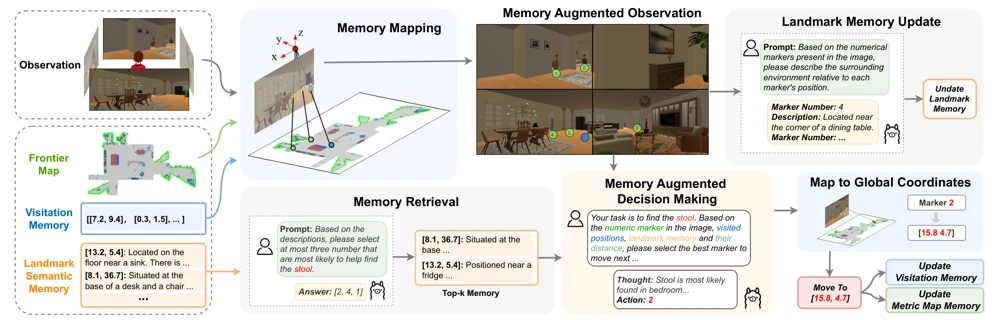 Mem2Ego: Empowering Vision-Language Models with Global-to-Ego Memory for Long-Horizon Embodied NavigationarXiv preprint arXiv:2502.14254, 2025
- ECCV
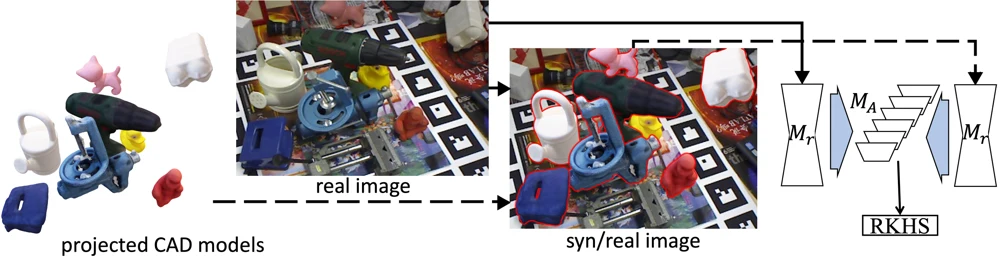 Pseudo-keypoint RKHS Learning for Self-supervised 6DoF Pose EstimationIn European Conference on Computer Vision, 2024
- WACV
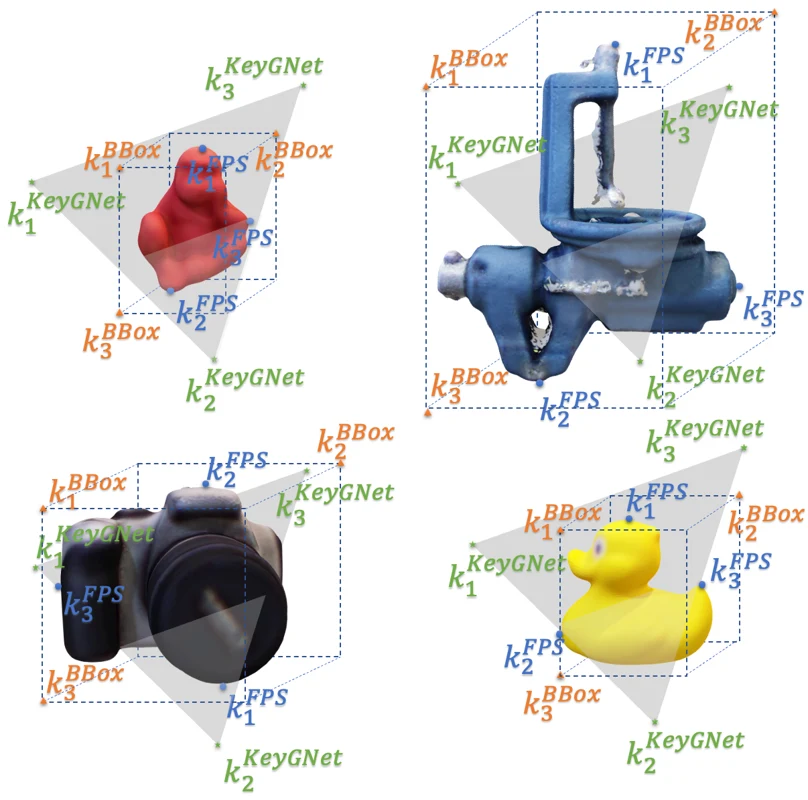 Learning Better Keypoints for Multi-Object 6DoF Pose EstimationIn Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision, 2024
- 3DV
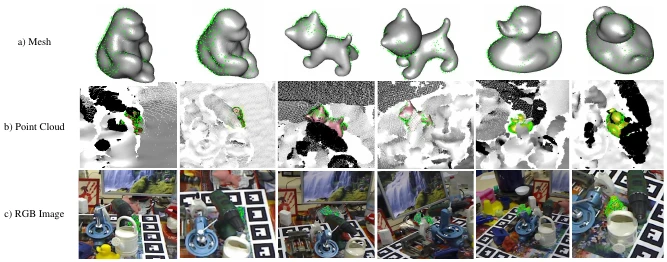 Keypoint Cascade Voting for Point Cloud Based 6DoF Pose EstimationIn International Conference on 3D Vision, 2022